.png?v=trim20261018)
1CONN Creative Reklam Ajansı
Sektörünüzle ilgili genel ve yerel bilgileri büyük bir titizlikle araştırıyor, sizin için gerçekleştireceğimiz çalışmalarımıza bu bilgiler ışığında yön veriyoruz. İlk düşündüğümüz; “Biz, bu markaya ne katabiliriz?”
Spacelike Loxodromes on Helicoidal Surfaces in Lorentzian n--Space
In this paper, we study three types of helicoidal surfaces in a Lorentzian n--space $\mathbb{E}^n_1$. First, we find the parametrizations of spacelike loxodromes on such spacelike helicoidal surfaces in $\mathbb{E}^n_1$. Then, we make a similar classification for spacelike loxodromes on such timelike helicoidal surfaces of a Lorentzian n--space $\mathbb{E}^n_1$.
New Approaches to Principal Component Analysis for Trees
Object Oriented Data Analysis is a new area in statistics that studies populations of general data objects. In this article we consider populations of tree-structured objects as our focus of interest. We develop improved analysis tools for data lying in a binary tree space analogous to classical Principal Component Analysis methods in Euclidean space. Our extensions of PCA are analogs of one dimensional subspaces that best fit the data. Previous work was based on the notion of tree-lines. In this paper, a generalization of the previous tree-line notion is proposed: k-tree-lines. Previously proposed tree-lines are k-tree-lines where k=1. New sub-cases of k-tree-lines studied in this work are the 2-tree-lines and tree-curves, which explain much more variation per principal component than tree-lines. The optimal principal component tree-lines were computable in linear time. Because 2-tree-lines and tree-curves are more complex, they are computationally more expensive, but yield improved data analysis results. We provide a comparative study of all these methods on a motivating data set consisting of brain vessel structures of 98 subjects.
Active Learning from Crowd in Document Screening
In this paper, we explore how to efficiently combine crowdsourcing and machine intelligence for the problem of document screening, where we need to screen documents with a set of machine-learning filters. Specifically, we focus on building a set of machine learning classifiers that evaluate documents, and then screen them efficiently. It is a challenging task since the budget is limited and there are countless number of ways to spend the given budget on the problem. We propose a multi-label active learning screening specific sampling technique -- objective-aware sampling -- for querying unlabelled documents for annotating. Our algorithm takes a decision on which machine filter need more training data and how to choose unlabeled items to annotate in order to minimize the risk of overall classification errors rather than minimizing a single filter error. We demonstrate that objective-aware sampling significantly outperforms the state of the art active learning sampling strategies.
Quasi--minimal surfaces of pseudo--Riemannian space forms with positive relative nullity
In this paper, we consider surfaces in 4--dimensional pseudo--Riemannian space--forms with index 2. First, we obtain some of geometrical properties of such surfaces considering their relative null space. Then, we get classifications of quasi--minimal surfaces with positive relative nullity.
Simultaneous Rational Periodic Points of Degree-2 Rational Maps
Let $S$ be the collection of quadratic polynomial maps, and degree $2$-rational maps whose automorphism groups are isomorphic to $C_2$ defined over the rational field. Assuming standard conjectures of Poonen and Manes on the period length of a periodic point under the action of a map in $S$, we give a complete description of triples $(f_1,f_2,p)$ such that $p$ is a rational periodic point for both $f_i\in S$, $i=1,2$. We also show that no more than three quadratic polynomial maps can possess a common periodic point over the rational field. In addition, under these hypotheses we show that two nonzero rational numbers $a, b $ are periodic points of the map $φ_{t_1,t_2}(z)=t_1 z + t_2/z$ for infinitely many nonzero rational pairs $(t_1, t_2)$ if and only if $a^2 = b^2$.
Trajectory Learning with Graph Representations for Social Robot Navigation
Autonomous mobile robots are expected to exhibit socially compliant navigation for minimizing pedestrian disturbance. While capturing social interactions and incorporating pedestrian motion estimations into decision-making are beneficial for compliance, prior methods fail to address both spatial and temporal characteristics present in real-world data. Reinforcement Learning offers high capability, but it requires hand-crafted reward functions that reduce social behavior to static criteria, limiting its ability to reproduce patterns that exist in real pedestrian behavior. Imitation Learning offers direct training from real-world data but lacks modeling of social interactions and suffers from error accumulation. To this end, we propose an imitation learning framework that leverages spatiotemporal dynamics for socially compliant navigation. To represent social context based on interactions, we introduce a graph-based auxiliary network that encodes crowd states by attending to pedestrians. In addition, we present a navigation module that captures temporal dynamics and mitigates error accumulations by incorporating encoded state predictions and employing a trajectory-level learning …
On e*$θ$-regular and e*$θ$-normal Spaces
The purpose of this study is to introduce a new class of regular spaces called e*$θ$-regular spaces which is a generalization of the class of $βθ$-regular spaces. Also, we investigate some basic properties and several characterizations of e*$θ$-regular and e*$θ$-normal spaces. Moreover, some functions such as e*$θ$-closed function, generalized e*$θ$-closed function, generalized e*$θ$-closed function have been defined and studied. Furthermore, we obtain some preservation theorems.
Rethinking and Recomputing the Value of Machine Learning Models
In this paper, we argue that the prevailing approach to training and evaluating machine learning models often fails to consider their real-world application within organizational or societal contexts, where they are intended to create beneficial value for people. We propose a shift in perspective, redefining model assessment and selection to emphasize integration into workflows that combine machine predictions with human expertise, particularly in scenarios requiring human intervention for low-confidence predictions. Traditional metrics like accuracy and f-score fail to capture the beneficial value of models in such hybrid settings. To address this, we introduce a simple yet theoretically sound "value" metric that incorporates task-specific costs for correct predictions, errors, and rejections, offering a practical framework for real-world evaluation. Through extensive experiments, we show that existing metrics fail to capture real-world needs, often leading to suboptimal choices in terms of value when used to rank classifiers. Furthermore, we emphasize the critical role of calibration in determining model value, showing that simple, well-calibrated models can often outperform …
Efficient Deep Reinforcement Learning with Predictive Processing Proximal Policy Optimization
Advances in reinforcement learning (RL) often rely on massive compute resources and remain notoriously sample inefficient. In contrast, the human brain is able to efficiently learn effective control strategies using limited resources. This raises the question whether insights from neuroscience can be used to improve current RL methods. Predictive processing is a popular theoretical framework which maintains that the human brain is actively seeking to minimize surprise. We show that recurrent neural networks which predict their own sensory states can be leveraged to minimise surprise, yielding substantial gains in cumulative reward. Specifically, we present the Predictive Processing Proximal Policy Optimization (P4O) agent; an actor-critic reinforcement learning agent that applies predictive processing to a recurrent variant of the PPO algorithm by integrating a world model in its hidden state. Even without hyperparameter tuning, P4O significantly outperforms a baseline recurrent variant of the PPO algorithm on multiple Atari games using a single GPU. It also outperforms other state-of-the-art agents given the same wall-clock time and exceeds human gamer performance on multiple …
Bour's Theorem of Spacelike Surfaces in Minkowski 4--Space
In this paper, we study on three kinds of spacelike helicoidal surfaces in Minkowski $4$--space. First, we give an isometry between such helicoidal surfaces and rotational surfaces which is a kind of generalization of Bour theorem in Minkowski $3$--space to Minkowski $4$--space. Then, we investigate geometric properties for such isometric surfaces having same Gauss map. By using these results, we give the parametrizations of isometric pair of surfaces. As a particular case, we examine the right helicoidal surfaces in view of Bour's theorem. Also, we present some examples by choosing the components of the profile curves and the parameters of the surfaces via Mathematica.
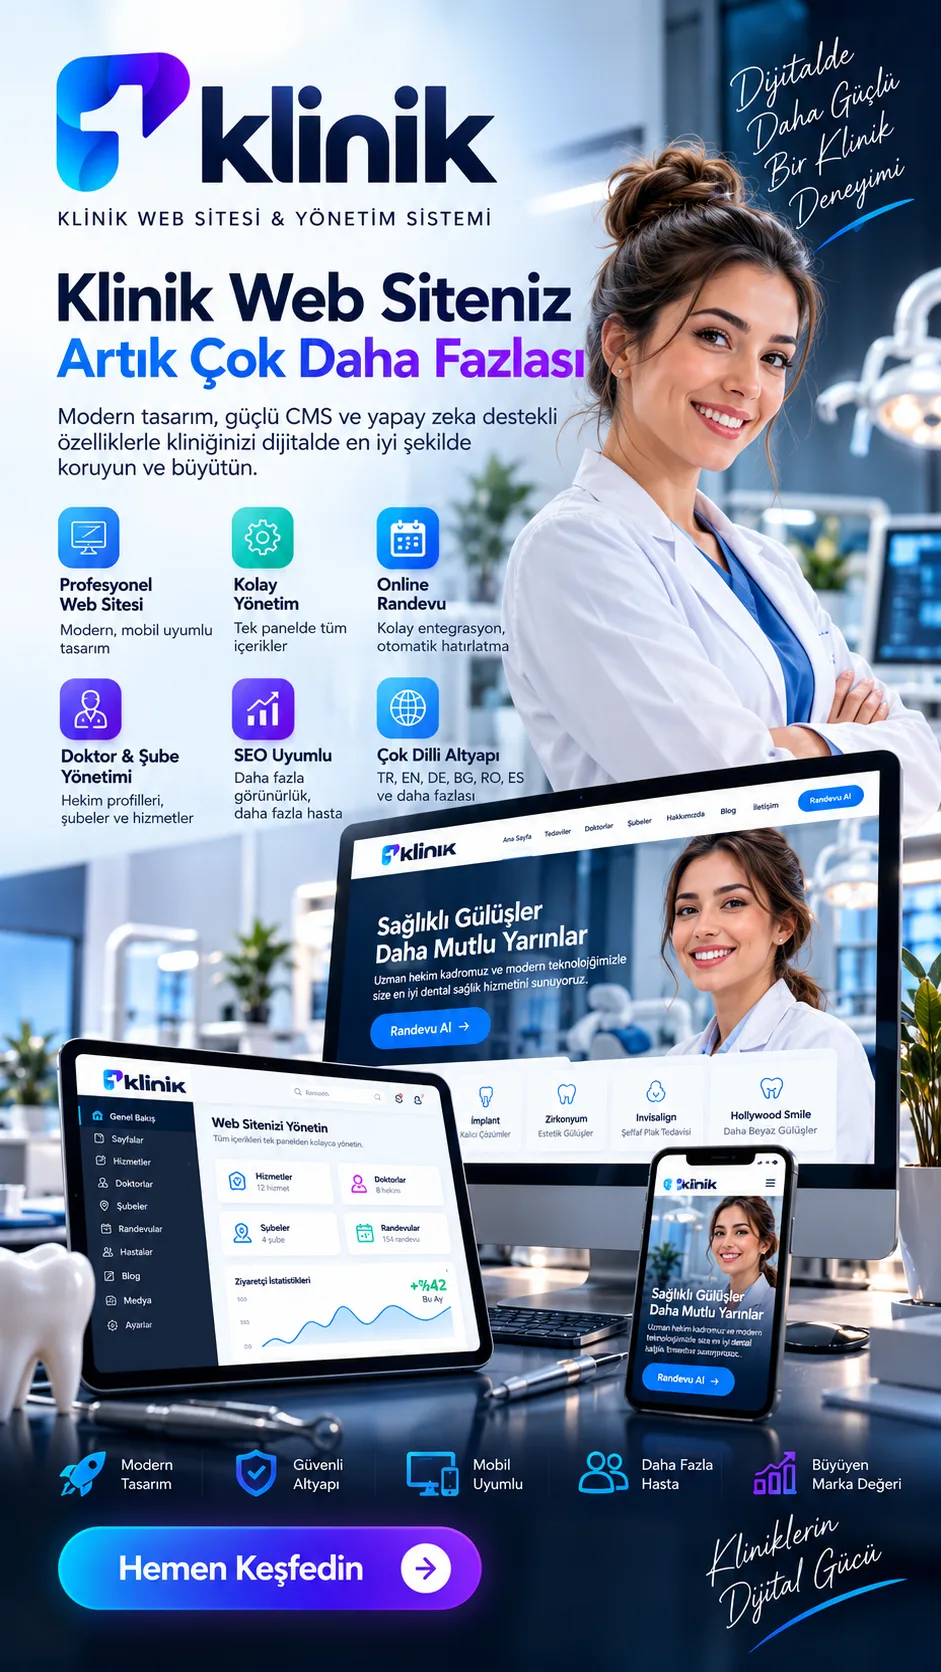
1Klinik CMS Web Yönetim Sistemi
Yeni Nesil Klinik Deneyimi. Bilim, teknoloji ve estetiği modern hasta deneyimiyle bir araya getiriyoruz. Dijital planlama, kişiye özel tedavi yaklaşımı ve güçlü hasta iletişimi.
Dentastik Klinik Yönetimi
Kliniğinizin tüm dünyası Tek bir akış. İlk temastan son kontrole. Satıştan tedaviye. Birbirine bağlı her an, tek ekosistemde.